Airflow as a Mechanism
AIr™ is the patented, drone-agnostic airflow cleaning method that uses a drone’s own rotor wash for waterless, non-contact surface maintenance. It combines aerodynamics, AI-driven control, and autonomous systems to extend aerial vehicles from inspection into useful physical work.
Most drones are used for imaging, inspection, or payload transport. AIr™ focuses on a different capability: using the drone’s inherent rotor downwash as the active working mechanism for cleaning and debris displacement on surfaces where physical contact, liquid use, or manual access are constrained.
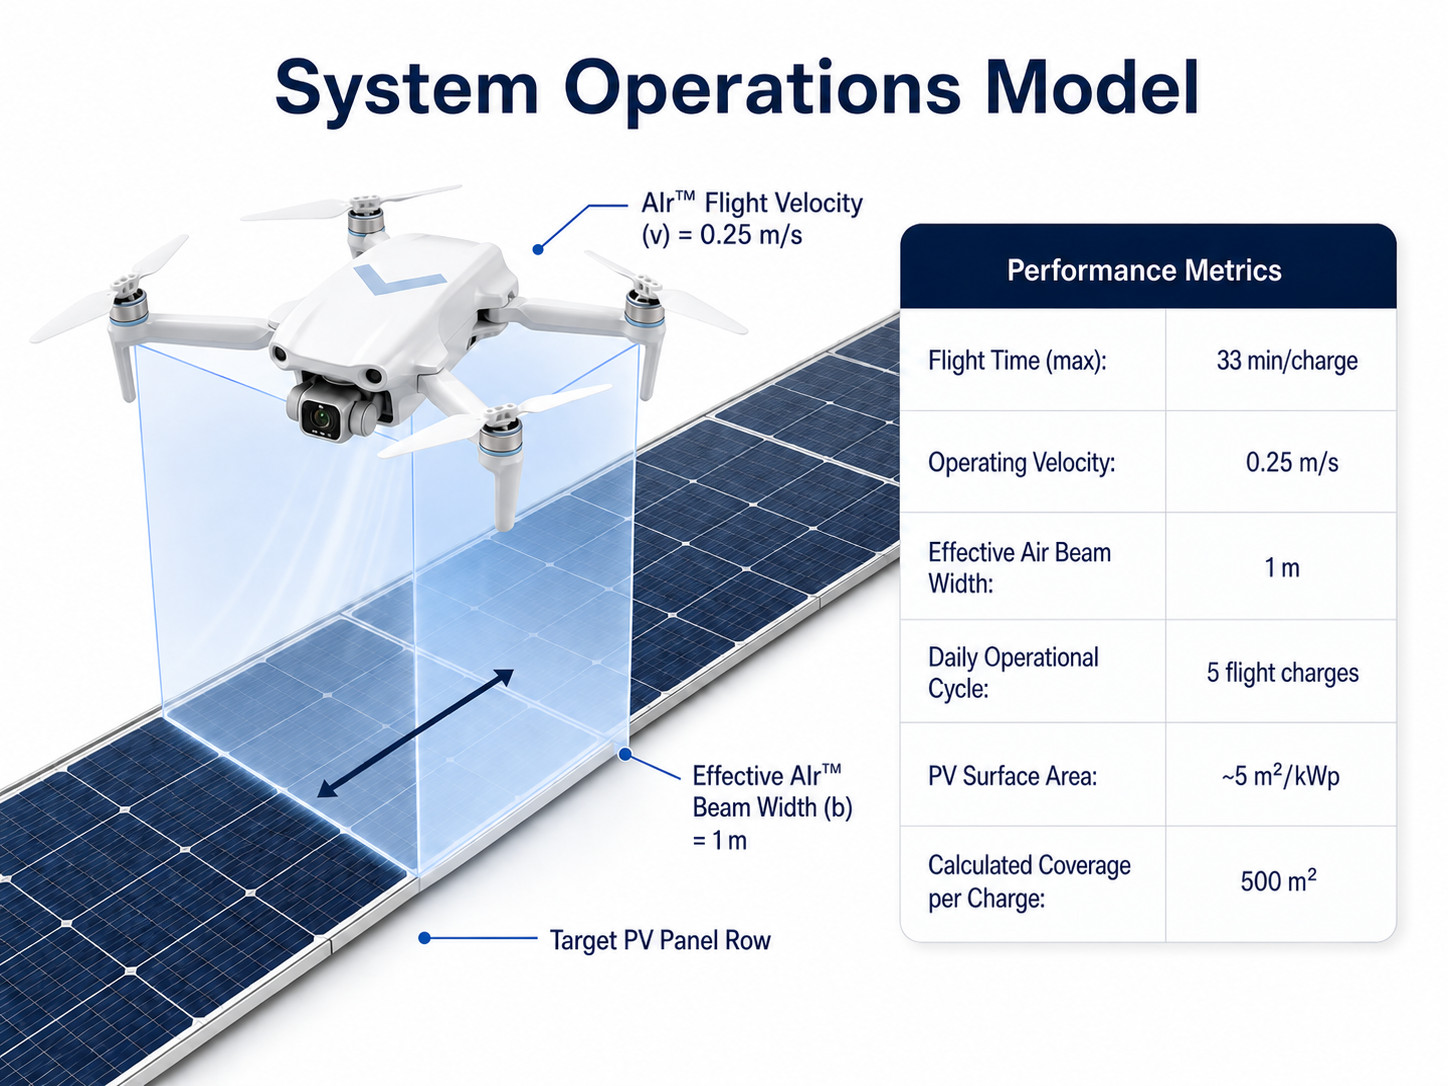
By managing drone position, altitude, orientation, and flight path, the method generates targeted airflow interactions that can remove dust, shift loose debris, or direct material toward collection zones — without brushes, water, or additional payload. This enables lightweight drone configurations to perform physical surface work while preserving the simplicity and efficiency of airflow-based cleaning.
AI, Vision & Aerodynamic Control
The AIr™ control stack draws on computational fluid dynamics (CFD), reinforcement learning, and computer vision to manage airflow interactions precisely.
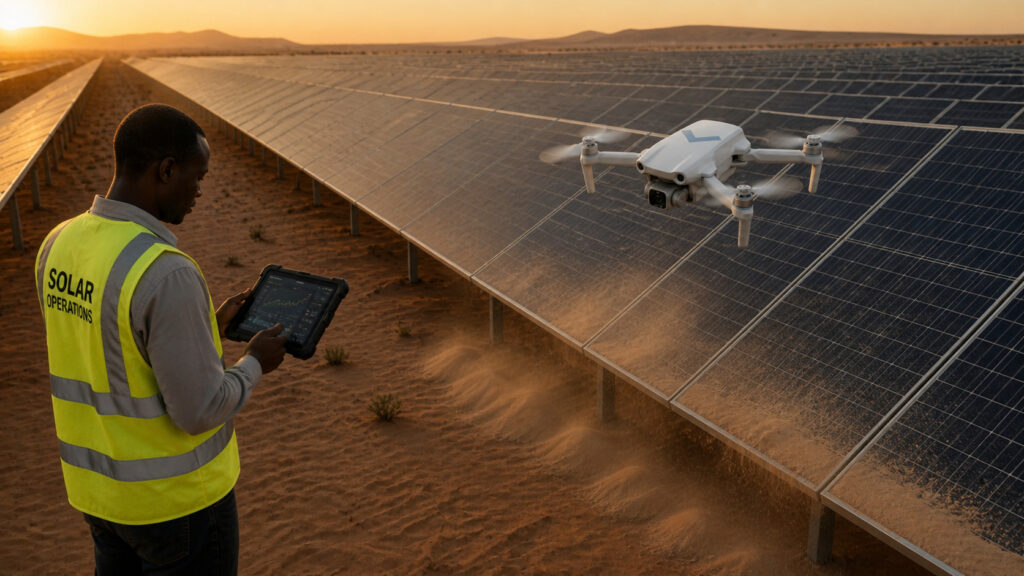
Reinforcement learning is used to refine flight paths and airflow exposure across varying surface geometries and soiling conditions. Field testing in Phoenix, Arizona, demonstrated significant dust removal after a single airflow exposure following three weeks without rain.
Computer vision and real-time sensing help identify soiling levels, surface boundaries, and environmental constraints in flight, enabling dynamic path adjustments without manual intervention. This control-layer focus fits our goal of advancing the patented method toward software and platform approaches, while leaving room for proprietary hardware integration.
CFD Analysis
Computational fluid dynamics is used to simulate how rotor wash interacts with different surfaces, panel spacings, debris sizes, and environmental conditions. This supports more consistent positioning, safer pressure management on delicate surfaces such as solar PV anti-reflective coatings or architectural glass, and highly predictable cleaning outcomes across diverse deployments.
Related Academic Work
Independent academic studies have since examined drone downwash as a mechanism for PV panel dust removal, supporting the physical principles of the AIr™ method:
- KFUPM (2022)
Study including Cleaning of Photovoltaic Panels Utilizing the Downward Thrust of a Drone (Energies) demonstrated that regular drone downwash flights remove accumulated dust and restore energy output. Tests in Dhahran, Saudi Arabia showed panel current increasing by up to 61.2% under specific horizontal drone movements. - ETH Zurich (2024)
A Characterization of the Induced Airflow around a Quadrotor (arXiv) provided a validated, computationally lightweight model of far-field rotor downwash. It describes jet structure, tip-to-tip scaling, and inter-rotor flow geometry.
These publications demonstrate that drone-generated airflow cleaning has since become a validated subject of independent technical investigation.
Applications
While solar energy remains a central use case, the method scales across multiple industries. See AIr™ applied across Energy & Utilities, the Built Environment, Agriculture, and Space & Beyond.