Airflow as a Mechanism
Every multirotor drone is, in effect, a flying fan: AIr™ harnesses its inherent rotor airflow as a patented, drone-agnostic method for waterless, non-contact surface maintenance. It combines aerodynamics, AI-driven control, and autonomous systems to extend aerial vehicles from inspection into useful physical work.
Most drones are used for imaging, inspection, or payload transport. AIr™ focuses on a different capability: using the drone’s own rotor downwash as the active working mechanism for cleaning and debris displacement on surfaces where physical contact, liquid use, or manual access are constrained.
By managing drone position, altitude, orientation, and flight path, the drone airflow cleaning method generates targeted airflow interactions that can remove dust, shift loose debris, or direct material toward collection zones without brushes, water, or additional payload. This enables lightweight drone configurations to perform physical surface work while preserving the simplicity and efficiency of airflow-based cleaning.
Preventive and Adaptive Cleaning
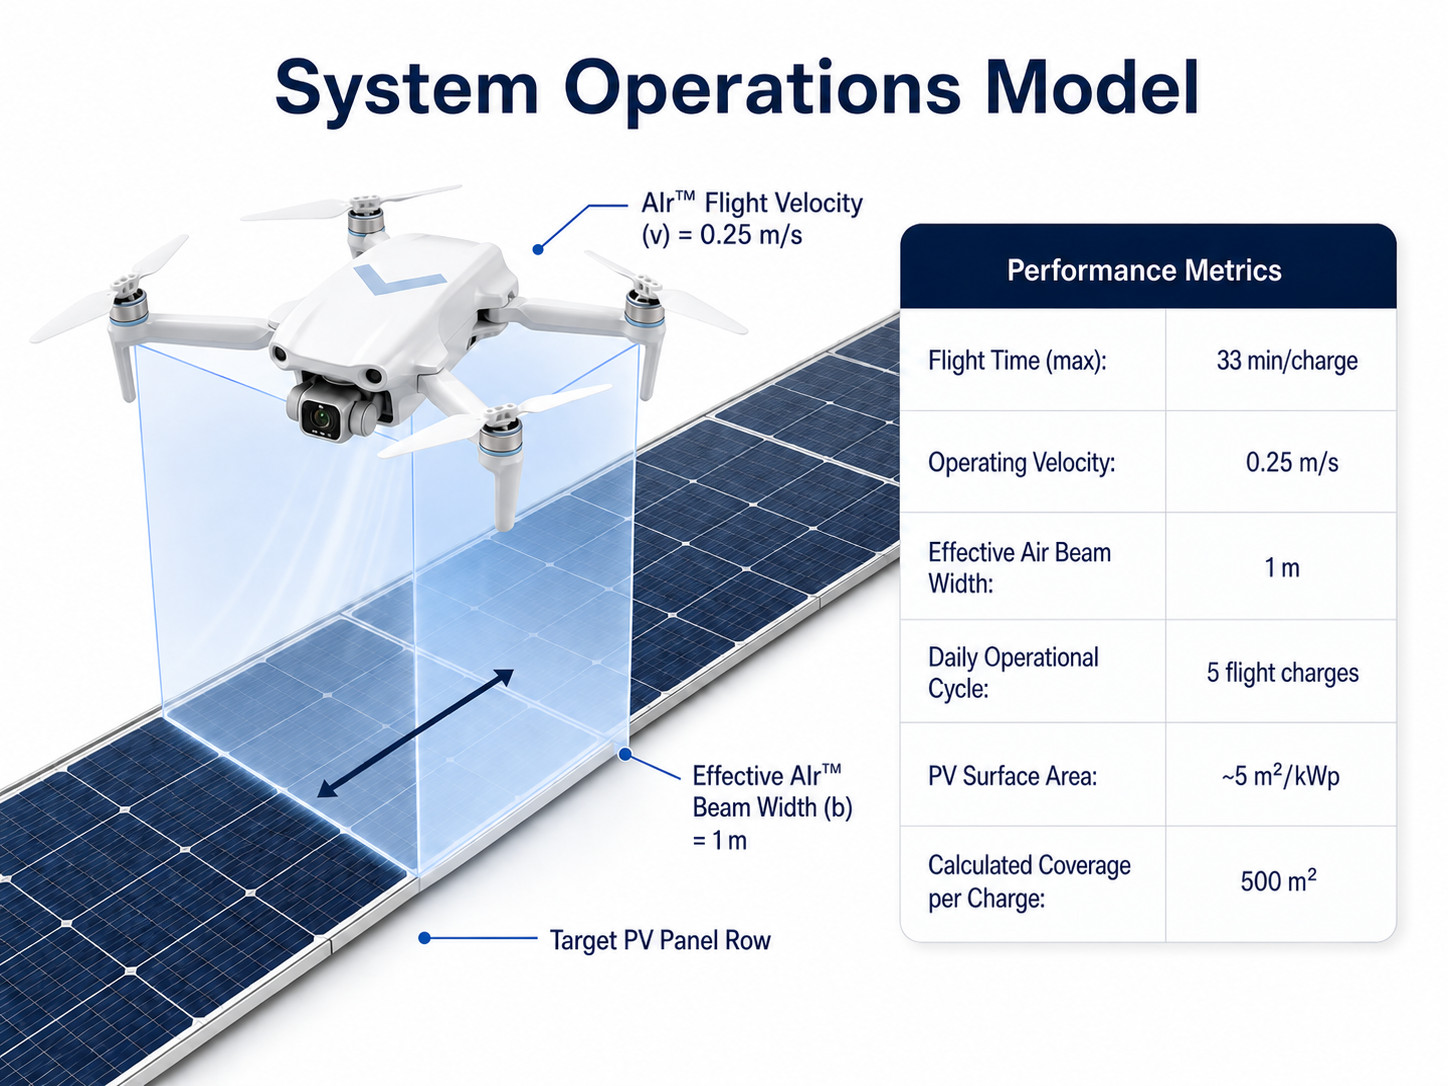
AIr™ is designed for repeatable preventive passes that remove loose dust before moisture can convert part of the deposit into more strongly adhered or cemented material. Because dew, humidity and dust composition vary by site, cleaning cadence is set according to local soiling and weather conditions rather than a fixed interval.
AIr™ is also building a fluidic response library: a structured record linking surface type, soiling conditions, weather, drone configuration, flight path and observed cleaning results. These observations are used to refine airflow exposure and flight paths for each surface and operating condition.
CFD Analysis
Computational fluid dynamics is used to simulate how rotor wash interacts with different surfaces, panel spacings, debris sizes, and environmental conditions. This supports more consistent positioning, safer pressure management on delicate surfaces such as solar PV anti-reflective coatings or architectural glass, and more informed airflow planning across diverse deployments.
AI, Vision & Aerodynamic Control
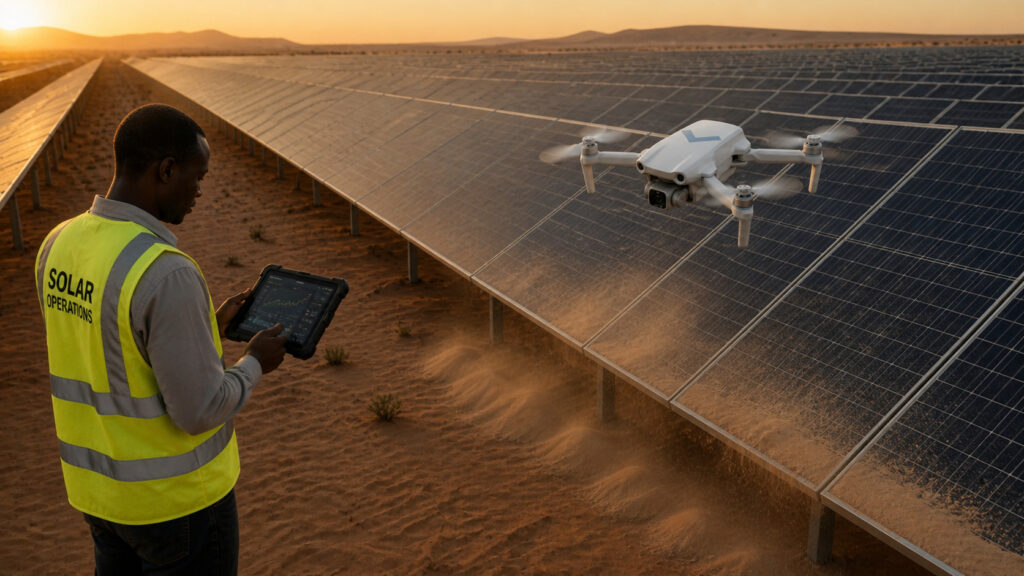
The AIr™ control stack draws on computational fluid dynamics (CFD), reinforcement learning, and computer vision to manage airflow interactions precisely. Reinforcement learning is used to refine flight paths and airflow exposure across varying surface geometries and soiling conditions.
Computer vision and real-time sensing help identify soiling levels, surface boundaries, and environmental constraints in flight, enabling dynamic path adjustments without manual intervention. This control-layer focus fits our goal of advancing the patented method toward software and platform approaches, while leaving room for proprietary hardware integration.
Related Academic Work
Independent academic studies have examined drone downwash, including its potential for PV panel dust removal, supporting the physical principles of the AIr™ method:
- KFUPM (2022)
Cleaning of Photovoltaic Panels Utilizing the Downward Thrust of a Drone (Energies) demonstrated that drone downwash removed dust from a PV panel and improved its output under the study’s test conditions. In one horizontal-flight test in Dhahran, Saudi Arabia, panel current increased by 61.2% after cleaning. - ETH Zurich (2024)
Robotics meets Fluid Dynamics: A Characterization of the Induced Airflow below a Quadrotor as a Turbulent Jet (arXiv) provided a validated, computationally lightweight model of far-field rotor downwash. It describes jet structure, tip-to-tip scaling, and inter-rotor flow geometry. - PowerChina (2026)
Autonomous UAV Swarm Maintenance for Dust and Hotspot Control in Photovoltaic Farms (Fluid Dynamics & Materials Processing) developed high-fidelity coupled CFD–FSI simulations to analyse aerodynamic downwash for dust detachment.
These publications show that drone-generated airflow cleaning and the underlying downwash physics have become subjects of independent technical investigation. See AIr™ applied across multiple industries such as Energy & Utilities, the Built Environment, Agriculture, and Space & Beyond.